Chapter 9 · Section 5
Beyond Light Speed — Phase Modulation Navigation
Advanced Navigation Through Computational Substrate
How can structured navigation through spacetime's computational substrate achieve effective velocities exceeding light speed while maintaining causal consistency and relativistic compliance? Binary Pulse Theory proposes that Prime Pulse Bifurcation ∅ → (0 ↔ 1) contains exploitable Phase Information within transition dynamics enabling sophisticated navigation without violating fundamental physical constraints — opening the door to advanced propulsion through computational manipulation.
This section proposes that while conventional matter cannot exceed light speed, phase manipulation through computational substrate enables effective displacement rates that can exceed 𝒞→ through geometric substrate properties rather than superluminal information transfer. The vehicle itself, like light, never moves faster than 𝒞→ through its local space, and no message outruns light; the effective rate comes from the route the substrate geometry offers. Building upon temporal resolution ①⥂⧗'⌂ = ①⥂⧗⌂ × f(ρ⦰) [𝕋] from Part 9.2, where ①⥂⧗⌂ = t_P = (ℏG/c⁵)^(1/2) [𝕋] establishes fundamental Pulse timing, Transition Phases within each Pulse Rhythm ①⥂⧖⌂ = α × ①⥂⧗⌂ [𝕋] encode continuous parameters manipulable for Computational Substrate Navigation.
Extending Parametric Inheritance mechanisms from Part 9.3, where phase characteristics propagate across cosmic generations, Phase Modulation Capability (G) represents higher-order application of resolution gradient mapping principles governing dark matter dynamics. Penrose's mathematical Universe framework (Penrose, 2004)²¹ and Rovelli's relational quantum mechanics (Rovelli, 1996)²² frame physics in terms of relations between systems; in BPT, the Phase Coupling Equation C(φ₁, φ₂) = α cos(Δφ) + β sin(Δφ) [∅] describes inter-system correlations.
The fundamental insight recognizes that while Binary Endpoints (0,1) remain discrete, transition phases contain rich information structure following Information Conservation I⊚ = I▱ + Iℜ principles. Synchronized Phase Manipulation (G) allows effective displacement rates through geometric substrate properties while respecting causal boundaries.
Phase Transition Architecture and Information Encoding
Phase Transition Architecture reveals how timing parameters shape information encoding within the substrate. Each cycle balances two scales of temporal definition: the Pulse Rhythm, which captures the half-cycle binary transition, and the Pulse Tempo (T⥂) (G), which spans the full 0 → 1 → 0 computation. By establishing this relationship — T⥂ = 2 × ①⥂⧖ — Binary Pulse Theory anchors its temporal framework in Planck time while showing how scaling factors carry forward inherited resolution across generations.
Pulse Rhythm (①⥂⧖)
①⥂⧖⌂ = α × ①⥂⧗⌂ [𝕋]
Dimensional analysis:
[𝕋]
[∅] × [𝕋] = [𝕋]
[𝕋] = [𝕋] ✓ Valid PulseCore Verified ✓
Pulse Tempo (T⥂)
T⥂ = 2 × ①⥂⧖⌂ = 2α × ①⥂⧗⌂ [𝕋]
Where:
- ①⥂⧖⌂ [𝕋] - Local Pulse Rhythm (half-cycle time, fundamental binary transition)
- α [∅] - Rhythm fraction, ½ exactly (one transition is half the Tempo)
- ①⥂⧗⌂ [𝕋] - Local Pulse Tempo (Planck time, baseline temporal resolution)
- T⥂ [𝕋] - Pulse Tempo (full 0 → 1 → 0 cycle)
- 2 [∅] - cycle multiplication factor
- 0 [∅] - binary state zero
- 1 [∅] - binary state one
Dimensional analysis:
Where (from the book): 0 [∅], 1 [∅], 2 [∅], α [∅]
[𝕋]
[∅] × [𝕋] = [𝕋]
[∅] × [∅] × [𝕋] = [∅] × [𝕋] = [𝕋]
[𝕋] = [𝕋] = [𝕋] ✓ Valid PulseCore Verified ✓
➢ Pulse Timing Parameters (G) establish fundamental binary transition timing through Planck time scaling, with Pulse Rhythm representing half-cycle binary transitions and Pulse Tempo encompassing full computational cycles, demonstrating how scaling factors establish temporal resolution inheritance that characterizes binary computational timing in substrate architectures.
Pulse Phase Function G
⥂⟢(t) = A × sin(2π × t/τ + φ₀) × H(t) [∅]
Where:
- ⥂⟢(t) [∅] – pulse phase function
- A [∅] – transition amplitude within Pulse Tempo
- sin [∅] – sine function
- 2π [∅] – angular period constant
- t [𝕋] – time parameter (t ∈ [0, T⥂] for each transition)
- τ [𝕋] – fundamental period parameter (①⥂⧗⌂)
- φ₀ [∅] – initial phase offset inherited from parent Universe geometry
- H(t) [∅] – Heaviside function constraining transition to T⥂
- T⥂ [𝕋] – Pulse Tempo (2 × Pulse Rhythm = 2α × ①⥂⧗⌂)
- ①⥂⧖⌂ [𝕋] – Local Pulse Rhythm (α × ①⥂⧗⌂)
- α [∅] – Rhythm fraction (½)
- ①⥂⧗⌂ [𝕋] – Local Pulse Tempo (Planck time)
- 0 [𝕋] – time lower bound
Dimensional analysis:
Where (from the book): 0 [𝕋], A [∅], sin [∅], 2π [∅], t [𝕋], τ [𝕋], H(t) [∅], α [∅]
[∅]
[∅] × [∅]([∅] × [𝕋] ÷ [𝕋] + [∅]) × [∅] = [∅] × [∅]([𝕋] ÷ [𝕋] + [∅]) × [∅] = [∅] × [∅]([∅] + [∅]) × [∅] = [∅] × [∅]([∅]) × [∅] = [∅] × [∅] × [∅] = [∅] × [∅] = [∅]
[∅] = [∅] ✓ Valid PulseCore Verified ✓
➢ Phase information encoded within Pulse transitions enables navigation through geometric substrate manipulation rather than conventional acceleration, demonstrating how sinusoidal phase encoding establishes geometric navigation that characterizes substrate manipulation-based movement through phase information rather than acceleration mechanisms in substrate architectures.
Transition Parameter Encoding utilizes multiple phase variables:
- δt↑ [𝕋] - duration of 0→1 transition within ①⥂⧖
- δt↓ [𝕋] - duration of 1→0 transition within the returning Rhythm (the second half of the Tempo ①⥂⧗)
- S∠ [J/(K·s)] - dS/dt during transition phases
- φ⇉ [rad] - relative phase between coupled systems
Information Capacity per Pulse quantifies encoding potential, following Sorkin's causal set theory (Sorkin, 2007)²³:
Information Capacity per Pulse G
I⟢ = log₂(N↑ × N↓ × N∠ × N⇉) · ℨᵇ [1ᵇ]
Where:
- I⟢ [1ᵇ] - information capacity per pulse
- log₂ [∅] - logarithm base 2 function
- N↑ [∅] - discrete resolution levels for rise parameter
- N↓ [∅] - discrete resolution levels for fall parameter
- N∠ [∅] - discrete resolution levels for slope parameter
- N⇉ [∅] - discrete resolution levels for alignment parameter
- 2 [∅] - logarithmic base
Dimensional analysis:
Where (from the book): 2 [∅], log₂ [∅], N↑ [∅], N↓ [∅], N∠ [∅], N⇉ [∅]
[1ᵇ]
[∅]([∅] × [∅] × [∅] × [∅]) × [1ᵇ] = [∅]([∅] × [∅] × [∅]) × [1ᵇ] = [∅]([∅] × [∅]) × [1ᵇ] = [∅]([∅]) × [1ᵇ] = [∅] × [1ᵇ] = [1ᵇ]
[1ᵇ] = [1ᵇ] ✓ Valid PulseCore Verified ✓
➢ Each Pulse encodes navigational information through phase relationships, enabling predictive trajectory planning through computational substrate, demonstrating how discrete resolution level combinations establish information encoding that characterizes predictive navigation through phase relationship manipulation in substrate architectures.
Through this dual definition of Pulse Rhythm and Pulse Tempo, Binary Pulse Theory demonstrates that temporal granularity is not arbitrary but structurally encoded into the recursive cycle itself. Information capacity emerges from phase transitions, while navigation and trajectory control arise from sinusoidal encoding. In this way, the fundamental timing relationship between Rhythm and Tempo becomes the backbone of predictive information flow, indicating that the substrate encodes both computation and geometry directly into the rhythm of its pulses.
Phase Projection Navigation Framework
Phase Projection Navigation extends the substrate’s timing logic into a spatial framework, showing how system states evolve not only through position and momentum but also through phase alignment. By targeting precise shifts in phase relative to local Pulse-field configurations, the framework establishes predictive navigation, where trajectories are calculated in advance rather than reacted to in real time. The Phase Projection Operator enables predictive navigation through substrate manipulation.
Phase Projection Operator G
S_{n+1} = P̂[Sₙ, Δφ✱, R⌂]
Where:
- S_{n+1} [mixed units] - predicted next state through evolution
- P̂ [functional operator] - phase projection operator
- Sₙ [mixed units] - current system state vector ([position, momentum, phase]ᵀ)
- Δφ✱ [∅] - desired phase shift vector
- R⌂ [∅] - local Pulse-field configuration (analogous to Resolution Function R(x,t))
- n [∅] - evolution step index
- position [𝕃] - spatial coordinate component
- momentum [𝕄·𝕃·𝕋⁻¹] - momentum component
- phase [∅] - phase component
➢ Phase projection enables predictive trajectory planning through computational substrate, allowing navigation along the shorter routes the substrate geometry offers, never arriving ahead of light on the same route, demonstrating how phase projection establishes advanced navigation that characterizes trajectory prediction through computational substrate manipulation via phase targeting in substrate architectures.
Through this operator, Binary Pulse Theory demonstrates that navigation can be achieved by manipulating phase itself, bypassing conventional speed constraints. Position, momentum, and phase are woven into a single predictive state vector, suggesting that advanced trajectory control and speed enhancement arise naturally from phase targeting within the substrate’s recursive architecture.
Navigation Through Phase Synchronization
Navigation through phase synchronization begins with the recognition that movement across the substrate is not achieved by acceleration in the classical sense, but by aligning internal phase states with the geometry of the underlying Pulse field. By satisfying the Synchronization Condition, a vehicle locks its oscillatory state to the substrate’s phase structure, enabling controlled trajectory shaping through phase offset manipulation. The Synchronization Condition requires phase alignment between vehicle and substrate.
Synchronization Condition G
φ⛟(t) = φ▱(x,t) + Δφ⇄ [rad]
Where:
- φ⛟(t) [∅] - vehicle phase state
- φ▱(x,t) [∅] - substrate phase field
- Δφ⇄ [∅] - control phase offset
- t [𝕋] - time variable
- x [𝕃] - spatial position vector
Dimensional analysis:
Where (from the book): φ⛟(t) [∅], φ▱(x,t) [∅], Δφ⇄ [∅], t [𝕋], x [𝕃]
[∅]
[∅] + [∅] = [∅]
[∅] = [∅] ✓ Valid PulseCore Verified ✓
➢ Synchronization Condition establishes vehicle phase state coordination with substrate phase field through control phase offset manipulation, demonstrating how phase synchronization enables controlled navigation that characterizes coordinated phase relationships for maintaining synchronized substrate operation in computational architectures.
Trajectory Optimization determines optimal paths through phase space:
Trajectory Optimization G
x✱(t) = ∫₀ᵗ v⟢(τ) dτ [𝕃]
Dimensional analysis:
Where (from the book): ₀ [𝕋], t [𝕋], τ [𝕋], x [𝕃]
Read dimensionally: x✱(t) = v⟢(τ) × (τ)
[𝕃]
[𝕃·𝕋⁻¹] × ([𝕋]) = [𝕃·𝕋⁻¹] × [𝕋] = [𝕃]
[𝕃] = [𝕃] ✓ Valid PulseCore Verified ✓
v⟢(τ) = (∂φ▱/∂t) / (∂φ▱/∂x) [𝕃·𝕋⁻¹]
Where:
- x✱(t) [𝕃] - optimal trajectory position
- ∫ [∅] - integration operator
- ₀ [𝕋] - integration lower limit
- t [𝕋] - time variable
- v⟢(τ) [𝕃·𝕋⁻¹] - phase velocity through substrate
- τ [𝕋] - integration variable
- 𝒞→ [𝕃·𝕋⁻¹] - speed of light
- ∂φ▱/∂x [𝕃⁻¹] - spatial phase gradient
- ∂φ▱/∂t [𝕋⁻¹] - temporal phase gradient
- φ▱ [∅] - substrate phase field
- x [𝕃] - spatial position vector
Dimensional analysis:
Where (from the book): ₀ [𝕋], t [𝕋], τ [𝕋], x [𝕃]
[𝕃·𝕋⁻¹]
([𝕋⁻¹]) ÷ ([𝕃⁻¹]) = [𝕋⁻¹] ÷ [𝕃⁻¹] = [𝕃·𝕋⁻¹]
[𝕃·𝕋⁻¹] = [𝕃·𝕋⁻¹] ✓ Valid PulseCore Verified ✓
➢ Navigation at Phase Wave Propagation Speeds through substrate geometry allows navigation along the shorter routes the substrate geometry offers, never arriving ahead of light on the same route, demonstrating how phase velocity integration establishes advanced navigation that characterizes trajectory optimization through substrate geometry while preserving causality in substrate architectures.
When trajectory optimization is applied on top of synchronization, the vehicle effectively rides the substrate’s phase waves, taking the shorter routes the substrate geometry offers, never arriving ahead of light on the same route. This reveals that true navigation lies in harmonizing with the substrate’s recursive oscillations, suggesting that controlled phase relationships are the key to unlocking predictive pathways along shorter routes while maintaining coherence within the Binary Pulse framework.
Relativistic Constraints and Substrate Compliance
Relativistic constraints impose the fundamental boundary conditions for navigation within the substrate, ensuring that all phase-based dynamics remain consistent with causality. By extending substrate phase behavior into relativistic field formulations, Binary Pulse Theory demonstrates how compliance with established constants — from the speed of light to the gravitational constant — anchors advanced navigation frameworks within physical law.
Substrate Phase Dynamics follow field equations maintaining relativistic consistency, building upon Ashtekar and Lewandowski's background-independent quantum gravity (Ashtekar & Lewandowski, 2004)⁶:
Substrate Phase Dynamics G
∇²φ = (1/𝒞→²) × (∂²φ/∂t²) + ρ⥂ × (4πG/𝒞→²) [rad/m²]
Dimensional analysis:
Where (from the book): 1 [∅], φ [∅], 4π [∅], G [𝕄⁻¹·𝕃³·𝕋⁻²], μ⟢ [MLT⁻²I⁻²], J⟢ [IL⁻²], t [𝕋]
Read dimensionally: (φ/x²) = (1/𝒞→²) × (∂²φ/∂t²) + ρ⥂ × (4π × G/𝒞→²)
([∅] ÷ [𝕃²]) = [𝕃⁻²]
([∅] ÷ [𝕃²·𝕋⁻²]) × ([𝕋⁻²]) + [𝕄·𝕃⁻³] × ([∅] × [𝕄⁻¹·𝕃³·𝕋⁻²] ÷ [𝕃²·𝕋⁻²]) = [𝕃⁻²·𝕋²] × [𝕋⁻²] + [𝕄·𝕃⁻³] × ([∅] × [𝕄⁻¹·𝕃³·𝕋⁻²] ÷ [𝕃²·𝕋⁻²]) = [𝕃⁻²] + [𝕄·𝕃⁻³] × ([∅] × [𝕄⁻¹·𝕃³·𝕋⁻²] ÷ [𝕃²·𝕋⁻²]) = [𝕃⁻²] + [𝕄·𝕃⁻³] × ([𝕄⁻¹·𝕃³·𝕋⁻²] ÷ [𝕃²·𝕋⁻²]) = [𝕃⁻²] + [𝕄·𝕃⁻³] × [𝕄⁻¹·𝕃] = [𝕃⁻²] + [𝕃⁻²] = [𝕃⁻²]
[𝕃⁻²] = [𝕃⁻²] ✓ Valid PulseCore Verified ✓
∇ × A⟢ = μ⟢ × J⟢ [rad/m²]
Where:
- ∇² [𝕃⁻²] - Laplacian operator
- φ [∅] - substrate phase field
- 1 [∅] - unity constant
- 𝒞→ [𝕃·𝕋⁻¹] - speed of light
- ∂²φ/∂t² [𝕋⁻²] - second temporal derivative of phase
- ρ⥂ [𝕄·𝕃⁻³] - Pulse density in local spacetime following substrate density
- 4π [∅] - geometric factor
- G [𝕄⁻¹·𝕃³·𝕋⁻²] - gravitational constant
- ∇ × [𝕃⁻¹] - curl operator
- A⟢ [𝕃⁻¹·𝕋] - phase vector potential encoding navigation relationships
- μ⟢ [MLT⁻²I⁻²] - phase permeability constant characterizing substrate properties
- J⟢ [IL⁻²] - phase current density describing information flow
- t [𝕋] - time variable
➢ Phase dynamics follow relativistic field equations ensuring causal consistency while enabling advanced navigation capabilities, demonstrating how wave equation evolution and curl relationships establish substrate navigation that characterizes advanced capabilities while maintaining relativistic causality through field equation compliance in substrate architectures.
Even where dimensional inconsistencies highlight the limits of direct analogies, the broader principle holds: phase evolution must remain tethered to relativistic compliance. This guarantees that while substrate manipulation may enable novel forms of trajectory control, the underlying framework never violates causal order. In this light, relativistic constraint emerges not as a barrier but as the stabilizing architecture that legitimizes phase-driven navigation within Binary Pulse Theory.
Navigation Implementation and Quantum Integration
Navigation within the substrate unfolds across multiple operational modes, each defined by how phase information is engaged and optimized. From simple local synchronization to full mesh integration, these classifications articulate the spectrum of control strategies available for phase-based traversal. By grounding each mode in Binary Pulse Theory while extending into canonical quantization approaches, the framework situates navigation as both a practical and quantum-coherent endeavor.
Navigation Mode Classifications (G) provide operational frameworks, connecting to Thiemann's canonical quantization of gravity (Thiemann, 2007):
Mode | Phase Parameters | Advantages | Limitations |
|---|---|---|---|
φ⇉ only | Simple control | Limited range | |
Gradient Riding (G) | ∇φ optimization | High efficiency | Requires mapping |
φ▷ prediction | Long-range capability | Complex computation | |
Full phase topology | Maximum flexibility | High data requirements |
Where:
- φ⇉ [∅] - phase alignment parameter
- ∇φ [𝕃⁻¹] - phase gradient optimization
- φ▷ [∅] - future phase prediction parameter
➢ Navigation Mode Classifications (G) establish operational frameworks through phase parameter optimization strategies, demonstrating how different navigation approaches balance control complexity with capability range that characterizes navigation strategy selection from simple local synchronization to complex mesh navigation with maximum flexibility in substrate architectures.
Quantum Phase Coupling G
|ψ⌭⟩ = Σₙ αₙ × exp(i × φₙ) × |n⟩ [∅]
Where:
- |ψ⌭⟩ [∅] - navigation quantum state
- Σ [∅] - summation operator
- n [∅] - basis state index
- αₙ [∅] - amplitude coefficients (satisfying Σ_n |α_n|² = 1)
- exp [∅] - exponential function
- i [∅] - imaginary unit
- φₙ [∅] - phase angles from BPT analysis
- |n⟩ [∅] - computational basis states
- 1 [∅] - normalization constant
Dimensional analysis:
Where (from the book): 1 [∅], |ψ⌭⟩ [∅], Σ [∅], n [∅], exp [∅], i [∅], φₙ [∅], |n⟩ [∅]
Read dimensionally: |ψ⌭⟩ = αₙ × exp(i × φₙ) × |n⟩
[∅]
[∅] × [∅]([∅] × [∅]) × [∅] = [∅] × [∅]([∅]) × [∅] = [∅] × [∅] × [∅] = [∅] × [∅] = [∅]
[∅] = [∅] ✓ Valid PulseCore Verified ✓
➢ Quantum phase coupling enables coherent navigation through computational substrate while maintaining quantum mechanical consistency, demonstrating how quantum state superposition with BPT phase analysis establishes coherent navigation that characterizes quantum mechanical consistency preservation during substrate navigation in computational architectures.
Taken together, the spectrum of navigation modes and their quantum integration demonstrate that control of movement through the substrate is not limited to classical alignment, but extends into superposed, phase-coherent states. This reveals that advanced navigation rests upon a continuum: from discrete phase alignment toward fully entangled, mesh-level orchestration. In this light, navigation becomes not only a problem of control, but an emergent expression of quantum integration within Binary Pulse Theory.
Interdomain Travel — Tuning Into Another Domain
The navigation above stays inside one domain: a vehicle locks to the substrate’s phase and rides the routes its geometry offers, never arriving ahead of light on the same route. The UniSphere offers a second road. Its grid stands at every harmonic level, each level a Harmonic Domain that spans the whole UniSphere (Part 1.9), and every one is built on the same grain: the pixel, one Zinf ℨ across, is the same in all of them (Part 1.11). A universe lives in a domain and is not one: the road a craft takes thirty levels down is that level’s grid, which reaches everywhere, not a universe of that level, which would be only a few hundred thousand kilometres across. Domains differ in how many pixels make one of their cells, the scaling s(⚚) = 2^⚚ × f^⚚, and so in how fast their light crosses the shared grid. Part 9.3 reads it: in the UniSphere’s own frame, pixels crossed per Zinf, every universe’s light moves at 1/s of its data, so one domain’s light, set beside another’s, moves at the inverse ratio of their scalings. A domain below ours carries light faster than ours, across the same pixels.
Interdomain Travel is the use of that difference. A craft tunes to a lower domain’s fundamental, crosses into it, covers the distance at that domain’s light, and tunes back to ours at the destination. Four laws set the road: the beat each domain keeps, the interval between neighbouring domains, the speed of their light, and the time a crossing takes.
Domain Fundamental G
ν(⚚) = 1 / (ℨ × 2^⚚ × f^⚚) [𝕋⁻¹]
Dimensional analysis:
Where (from the book): ν(⚚) [𝕋⁻¹], ℨ [𝕋], f [∅]
[𝕋⁻¹]
[∅] ÷ ([𝕋] × [∅]^([∅]) × [∅]^([∅])) = [∅] ÷ ([𝕋] × [∅] × [∅]^([∅])) = [∅] ÷ ([𝕋] × [∅]^([∅])) = [∅] ÷ ([𝕋] × [∅]) = [∅] ÷ [𝕋] = [𝕋⁻¹]
[𝕋⁻¹] = [𝕋⁻¹] ✓ Valid PulseCore Verified ✓
Each domain’s fundamental is one of its Tempos per cycle, ℨ × s(⚚)
Where:
- ν(⚚) [𝕋⁻¹] — the fundamental frequency of the domain at harmonic level ⚚
- ℨ [𝕋] — the Zinf, the full cycle of the grain (Z.2)
- ⚚ [∅] — the domain’s harmonic level, ⚚♁ = 202 for ours (Part 1.6)
- f [∅] — the null-well heritage, 1.018 (Part 1.8)
➢ A domain’s Tempo is ℨ × s(⚚), so its fundamental is the inverse. Ours, at ⚚♁, is 1/①⥂⧗♁ ≈ 1.85 × 10⁴³ Hz, the inverse of the Planck time. Every domain hears its own fundamental as the rate of its own clocks and finds nothing unusual in it; the differences show only when domains are set side by side in the UniSphere’s frame.
Domain Interval G
ν(⚚ − 1) / ν(⚚) = 2 × f [∅]
Dimensional analysis:
Where (from the book): ν(⚚ − 1) [𝕋⁻¹], ν(⚚) [𝕋⁻¹], f [∅]
[𝕋⁻¹] ÷ [𝕋⁻¹] = [∅]
[∅] × [∅] = [∅]
[∅] = [∅] ✓ Valid PulseCore Verified ✓
Each level down raises the fundamental by 2f, an octave sharpened by about 31 cents
Where:
- ν(⚚ − 1), ν(⚚) [𝕋⁻¹] — the fundamentals of neighbouring domains, one level apart
- 2 × f [∅] — one doubling times the heritage, 2.036
➢ The domains stand on a ladder of near-octaves. One step is 2.036, an octave sharpened by 1200 × log₂ 1.018 ≈ 30.9 cents, and Δ⚚ steps give (2f)^Δ⚚. Tuning between domains is stepping by that interval, and it is done by division: a craft that runs at the grain’s own rhythm, 1/ℨ, reaches any domain’s fundamental by dividing that rhythm by the domain’s scaling s(⚚).
Interdomain Light Ratio G
𝒞→(⚚) / 𝒞→♁ = (2 × f)^(⚚♁ − ⚚) [∅]
Dimensional analysis:
Where (from the book): 𝒞→(⚚) [𝕃·𝕋⁻¹], 𝒞→♁ [𝕃·𝕋⁻¹], f [∅]
[𝕃·𝕋⁻¹] ÷ [𝕃·𝕋⁻¹] = [∅]
([∅] × [∅])^([∅] - [∅]) = ([∅] × [∅])^([∅]) = [∅]^([∅]) = [∅]
[∅] = [∅] ✓ Valid PulseCore Verified ✓
In the UniSphere’s frame, a domain Δ⚚ levels below ours carries light (2f)^Δ⚚ times faster
Where:
- 𝒞→(⚚) [𝕃·𝕋⁻¹] — the light of the domain at level ⚚, read in the UniSphere’s frame
- 𝒞→♁ [𝕃·𝕋⁻¹] — our light in the same frame
- ⚚♁ − ⚚ [∅] — how many levels the domain stands below ours
➢ It is Part 9.3’s s/s′ with s(⚚) written out. Ten levels down, light crosses the shared grid about 1,220 times faster than ours; thirty levels down, 1.8 × 10⁹ times; at the Zinf domain itself, level 0, it reaches the grid’s own limit of one pixel per Zinf, about 2.4 × 10⁶² times ours, the ceiling of every interdomain road. Relativity forbids outrunning light because it has no preferred frame, so a signal faster than light would arrive before it left in some frame and loops in time would follow. Binary Pulse Theory has a preferred frame, the UniSphere’s pixels per Zinf, and every crossing keeps one order in it. A craft in a lower domain still never outruns the light of the domain it is in: it travels at that domain’s light. This is the one place the theory leaves our light behind, and it does so only by leaving our domain.
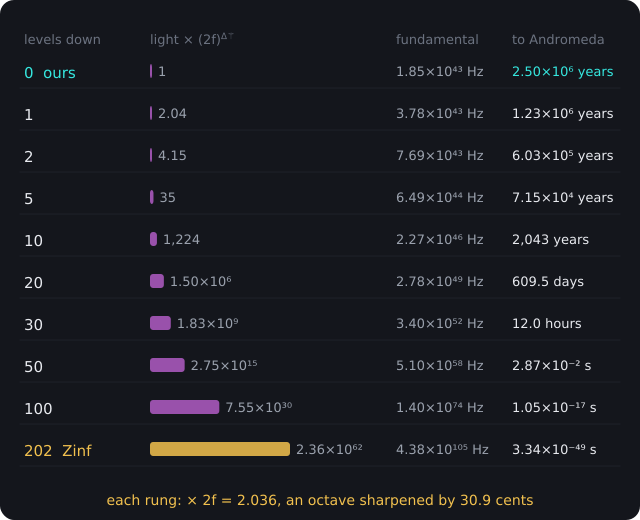
The Domain Ladder. Each harmonic level below ours raises a domain’s fundamental by 2f = 2.036, an octave sharpened by about 31 cents, and its light, in the UniSphere’s frame, by the same factor: 𝒞→(⚚) / 𝒞→♁ = (2f)^(⚚♁ − ⚚). Ten levels down, Andromeda is about 2,040 years away; thirty levels down, 12 hours; the Zinf domain, level 0, is the ceiling.
The Resonance Cascade — Tuning Time
Tuning down is not one jump. The craft steps through every level between ours and the target, and each step takes the Tempo of the domain it enters, so each step is 2f times shorter than the last: an accelerando, each note nearly an octave higher and about half as long. The pilot’s body steps with it, tuning to each new level as it heads for the faster ones, and comes to rest in resonance with the target domain for the crossing. The climb back is the same cascade in reverse.
Resonance Cascade G
τ⇅ = N⇅ × ①⥂⧗♁ × (1 − (2 × f)^(⚚ − ⚚♁)) / (2 × f − 1) [𝕋]
Dimensional analysis:
Where (from the book): τ⇅ [𝕋], N⇅ [∅], f [∅]
[𝕋]
[∅] × [𝕋] × ([∅] - ([∅] × [∅])^([∅] - [∅])) ÷ ([∅] × [∅] - [∅]) = [𝕋] × ([∅] - ([∅] × [∅])^([∅] - [∅])) ÷ ([∅] × [∅] - [∅]) = [𝕋] × ([∅] - ([∅] × [∅])^([∅])) ÷ ([∅] × [∅] - [∅]) = [𝕋] × ([∅] - [∅]^([∅])) ÷ ([∅] × [∅] - [∅]) = [𝕋] × ([∅] - [∅]) ÷ ([∅] × [∅] - [∅]) = [𝕋] × [∅] ÷ ([∅] × [∅] - [∅]) = [𝕋] ÷ ([∅] × [∅] - [∅]) = [𝕋] ÷ ([∅] - [∅]) = [𝕋] ÷ [∅] = [𝕋]
[𝕋] = [𝕋] ✓ Valid PulseCore Verified ✓
Each step takes one settling of the domain it enters; the steps shorten by 2f, and their sum stays finite
Where:
- τ⇅ [𝕋] — the time to tune from our domain down to level ⚚, one way
- N⇅ [∅] — the Tempos a body needs to settle at each level
- ①⥂⧗♁ [𝕋] — our Tempo, the Planck time
- (1 − (2 × f)^(⚚ − ⚚♁)) / (2 × f − 1) [∅] — the sum of the entered domains’ Tempos, in ours: Σ (2f)^(−j) for j = 1 … ⚚♁ − ⚚
➢ The steps form a geometric series, and a geometric series of shrinking terms has a finite sum however many terms it has: the whole descent takes at most N⇅ × ①⥂⧗♁ / (2f − 1), about 0.97 N⇅ Planck times. Even a body that needed a billion Tempos to settle at each level would reach the Zinf domain in about 5 × 10⁻³⁵ seconds. The tuning is effectively instantaneous, and the journey’s time is the lock at each end and the crossing.
Interdomain Transit Time G
t⇄ = 2 × (τ◇ + τ⇅) + d / (𝒞→♁ × (2 × f)^(⚚♁ − ⚚)) [𝕋]
Dimensional analysis:
Where (from the book): t⇄ [𝕋], τ◇ [𝕋], τ⇅ [𝕋], d [𝕃], 𝒞→♁ [𝕃·𝕋⁻¹], f [∅]
[𝕋]
[∅] × ([𝕋] + [𝕋]) + [𝕃] ÷ ([𝕃·𝕋⁻¹] × ([∅] × [∅])^([∅] - [∅])) = [∅] × [𝕋] + [𝕃] ÷ ([𝕃·𝕋⁻¹] × ([∅] × [∅])^([∅] - [∅])) = [𝕋] + [𝕃] ÷ ([𝕃·𝕋⁻¹] × ([∅] × [∅])^([∅] - [∅])) = [𝕋] + [𝕃] ÷ ([𝕃·𝕋⁻¹] × ([∅] × [∅])^([∅])) = [𝕋] + [𝕃] ÷ ([𝕃·𝕋⁻¹] × [∅]^([∅])) = [𝕋] + [𝕃] ÷ ([𝕃·𝕋⁻¹] × [∅]) = [𝕋] + [𝕃] ÷ [𝕃·𝕋⁻¹] = [𝕋] + [𝕋] = [𝕋]
[𝕋] = [𝕋] ✓ Valid PulseCore Verified ✓
Lock, cascade down, cross at the lower domain’s light, cascade up, lock
Where:
- t⇄ [𝕋] — the journey’s time, by our clocks
- τ◇ [𝕋] — the lock between pilot and craft, at departure and at arrival, N◇ / ν◇ (Binary Beat)
- τ⇅ [𝕋] — the Resonance Cascade, each way
- d [𝕃] — the distance, in our domain
- 𝒞→♁ × (2 × f)^(⚚♁ − ⚚) [𝕃·𝕋⁻¹] — the lower domain’s light, in our units
➢ Andromeda is 2.5 million light-years away: 2.5 million years at our light, about 2,040 years ten levels down, 12 hours thirty levels down, and three hundredths of a second fifty levels down, with a beat’s lock at each end; the cascade adds about a Planck time. Deeper is always faster, so what limits the depth of a journey is not time but the body that makes it: the Goldilocks Level and the Resonance Ceiling below. The depth a journey can reach is set by the craft and the body that make it, not by the theory.
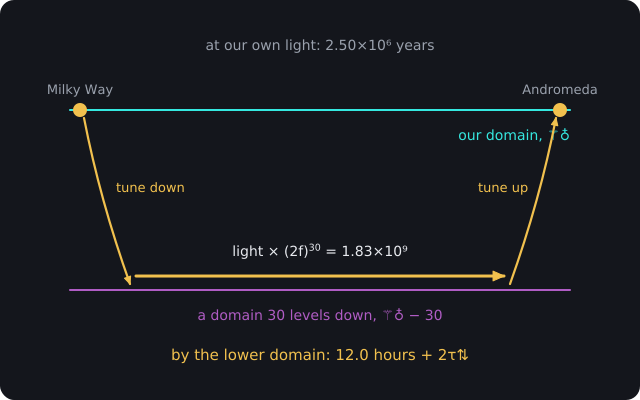
An Interdomain Journey. The craft tunes down to a domain thirty levels below ours, crosses at that domain’s light, (2f)³⁰ ≈ 1.8 × 10⁹ times ours in the UniSphere’s frame, and tunes back up at the destination: t⇄ = 2τ⇅ + d / (𝒞→♁ × (2f)^(⚚♁ − ⚚)). The 2.5 million light-years to Andromeda take about 12 hours, plus the time to tune twice.
The Craft — Built in Zinf Units
A craft made of our matter is built at our Planck scale and above, about 10⁶² pixels to one of our cells; in a lower domain its cells do not fit. A craft whose structure is defined in Zinf units belongs to no domain’s scale, and so to all of them. Crossing between domains does not take it apart. It re-times it: the craft changes which fundamental it locks to, and its structure stays as it is.
Such a craft is not assembled from atoms. It is written into the substrate directly, as pulses and data, the Data–Matter Equivalence (Part 2.9) used as engineering. A structure that computes at the grain is an intelligence by construction: the lattice that holds the craft together is the same lattice that runs it, and the craft is its own mind. Its pilot is matter in our units, and the pilot is not taken apart. The body is re-timed with the craft, level by level: by the Data–Matter Equivalence a body is data too, and the Resonance Cascade carries its pattern down in resonance with each domain it enters. Atoms do not survive the descent. More than about three and a half levels below ours, α(⚚) = α♁ × (2f)^(2 × (⚚♁ − ⚚)) is above 1 and atoms cannot hold (Part 1.16, One Dial), so in the deep domains the body exists as its resonating pattern, and it is atoms again on its way back up, the way a universe’s record enters its Pulsecore as a stream and is written out on the far side (Part 3.6).
The pilot’s DNA gives the craft the pilot’s own pattern. The human genome holds about 3.1 × 10⁹ base pairs, about 6.2 × 10⁹ bits. It is not the whole record of a person, but it is the key: the pattern the craft tunes the cascade to, so that it resonates with this person and no other, and the pattern the arrival check reads to measure how faithfully the body came through.
The Goldilocks Level and the Resonance Ceiling
Each level down makes the crossing 2.036 times faster, but that gain is in proportion: once the crossing is short, one more level saves almost nothing. In any real craft each step costs the body the same small price in fidelity, its pattern carried a little less exactly. Past some depth, one more level saves less time than it costs, as a car past about 55 miles an hour spends more fuel for each mile than the time it saves is worth. Unlike a car’s, the sweet spot moves with the trip.
Goldilocks Level G
(2 × f)^Δ⚚* = (d / 𝒞→♁) × ln(2 × f) / p⇅ [∅]
Dimensional analysis:
Where (from the book): Δ⚚* [∅], f [∅], d [𝕃], 𝒞→♁ [𝕃·𝕋⁻¹], p⇅ [𝕋]
([∅] × [∅])^([∅]) = [∅]^([∅]) = [∅]
([𝕃] ÷ [𝕃·𝕋⁻¹]) × ln([∅] × [∅]) ÷ [𝕋] = [𝕋] × ln([∅] × [∅]) ÷ [𝕋] = [𝕋] × ln([∅]) ÷ [𝕋] = [𝕋] × [∅] ÷ [𝕋] = [𝕋] ÷ [𝕋] = [∅]
[∅] = [∅] ✓ Valid PulseCore Verified ✓
The depth where one more level saves exactly what it costs
Where:
- Δ⚚* [∅] — the best number of levels down for a journey of length d
- d / 𝒞→♁ [𝕋] — the journey’s time at our light
- p⇅ [𝕋] — the price of one step: the fidelity it costs, −ln F⇅, weighed as the journey time a traveller would give to keep it
➢ It minimises p⇅ × Δ⚚ + (d / 𝒞→♁) × (2f)^(−Δ⚚), the steps’ price plus the crossing. At the best depth the crossing always takes the same time, p⇅ / ln(2f), whatever the distance, so by the clock every trip, near or far, is that crossing and a lock at each end. What grows with distance is the price: p⇅ × (Δ⚚* + 1 / ln 2f) in all, rising only with the logarithm of the distance, one level deeper for each factor of 2.036. Short hops stay shallow; every tenfold in distance adds about 3.2 levels. For a journey that takes less than p⇅ / ln(2f) at our own light, the best depth is zero: interdomain travel does not pay at all.
Resonance Ceiling G
Δ⚚max = ln(F_min) / ln(F⇅) [∅]
Dimensional analysis:
Where (from the book): Δ⚚max [∅], F_min [∅], F⇅ [∅]
[∅]
ln([∅]) ÷ ln([∅]) = [∅] ÷ ln([∅]) = [∅] ÷ [∅] = [∅]
[∅] = [∅] ✓ Valid PulseCore Verified ✓
The deepest level a body can reach and still arrive as itself
Where:
- Δ⚚max [∅] — the most levels a body can descend
- F⇅ [∅] — the fidelity of one step, the share of the body’s pattern carried exactly: a property of the craft
- F_min [∅] — the lowest whole-journey fidelity the arrival check accepts: a property of the body
➢ After Δ⚚ steps the body’s fidelity is F⇅^Δ⚚, and the ceiling is where that reaches F_min. The Goldilocks Level is the trip’s best depth and the ceiling the safe limit, the best-mileage speed and the top speed. A body that holds its pattern well can go deeper and so farther in the same time: how far a traveller can go depends on how coherently they hold together.
The theory itself permits a lossless step. Going down, each domain’s cells are finer than the last, and a pattern carried onto a finer grid loses nothing: a pattern smooth enough for one grid is fixed exactly by its samples on any finer one, whatever the ratio between them, even one as uneven as 2.036 (Shannon, 1949). Coming back up, the pattern is the one that left our grid, and it fits our cells exactly again; nothing is lost at any step, as Information Conservation requires. So F⇅ is not a law of nature but a measure of the craft, as efficiency is of an engine. A perfect craft has F⇅ = 1: no price per step, no ceiling, and every trip goes to the fastest domain the craft can reach. The Goldilocks Level and the Resonance Ceiling are the laws of real craft, which fall short of that, as 55 miles an hour is the law of real engines and not of motion. F_min, how much error a living body can carry and remain itself, belongs to biology; it is measured by those who build and test the craft, not given by the theory.
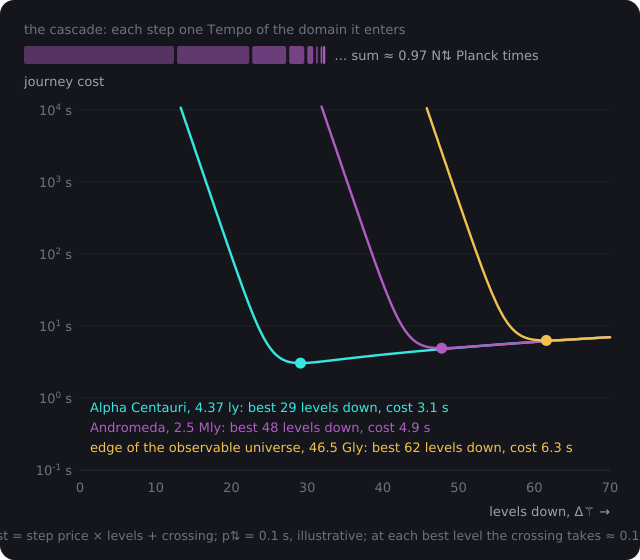
The Goldilocks Level. Above, the Resonance Cascade: each step one Tempo of the domain it enters, each 2f times shorter, summing to about one Planck time per settling. Below, the journey’s cost, the steps’ price plus the crossing, p⇅ × Δ⚚ + (d / 𝒞→♁)(2f)^(−Δ⚚), for three trips, with an illustrative step price of 0.1 s. Each curve’s lowest point is that trip’s best level: deeper for longer trips, the cost growing only with the logarithm of the distance, and the crossing there always about 0.14 s by the clock.
Binary Beat Loops G
The craft’s moving parts are two closed loops, each a figure-8, a lemniscate, the shape of ∞, stacked on the craft’s axis, the upper slightly larger, crossed at right angles and circulating in opposite senses. Each loop’s two lobes turn opposite ways, so a loop carries no net spin over a circuit, and the counter-circulating second loop cancels what remains within each circuit. With no net spin the craft has no gyroscopic stiffness: it can turn in any direction at once while its loops keep their energy.
The loops do not lift the craft. Spinning masses do not cancel weight: a 1989 report of gyroscopes weighing less when spun one way (Hayasaka & Takeuchi, 1989) was tested the next year by two independent groups, who found no change within their precision (Faller et al., 1990; Nitschke & Wilmarth, 1990). The craft needs no lift; it moves by changing domains. What the loops make is two notes.
Loop Note G
ν_k = v / ℓ_k [𝕋⁻¹]
Dimensional analysis:
Where (from the book): ν_k [𝕋⁻¹], v [𝕃·𝕋⁻¹], ℓ_k [𝕃]
[𝕋⁻¹]
[𝕃·𝕋⁻¹] ÷ [𝕃] = [𝕋⁻¹]
[𝕋⁻¹] = [𝕋⁻¹] ✓ Valid PulseCore Verified ✓
One carrier speed in both loops: the larger loop sounds the lower note, and the size ratio is the interval
Where:
- ν_k [𝕋⁻¹] — the rate at which loop k’s carrier passes the crossing
- v [𝕃·𝕋⁻¹] — the carrier speed, the same in both loops
- ℓ_k [𝕃] — loop k’s length; a lemniscate of half-width a is 2ϖ·a ≈ 5.244·a long
➢ With one carrier speed, ν₂ / ν₁ = ℓ₁ / ℓ₂ = a₁ / a₂: the ratio of the loops’ sizes is the musical interval between their notes. A loop only slightly larger sounds a note only slightly lower; an upper loop 8 % larger sits 133 cents below the lower one, a little more than a semitone.
Binary Beat G
ν◇ = |ν₁ − ν₂| [𝕋⁻¹]
Dimensional analysis:
Where (from the book): ν◇ [𝕋⁻¹], ν₁ [𝕋⁻¹], ν₂ [𝕋⁻¹]
Read dimensionally: ν◇ = (abs(ν₁ − ν₂))
[𝕋⁻¹]
(abs([𝕋⁻¹] - [𝕋⁻¹])) = (abs([𝕋⁻¹])) = [𝕋⁻¹]
[𝕋⁻¹] = [𝕋⁻¹] ✓ Valid PulseCore Verified ✓
Two close notes meet at the crossing and make a third rhythm, present in neither
Where:
- ν◇ [𝕋⁻¹] — the beat
- ν₁, ν₂ [𝕋⁻¹] — the two loops’ notes (Loop Note)
➢ Two tones of slightly different frequency, one to each ear, are heard as a third rhythm at their difference, present in neither tone: the binaural beat, formed where the signals of the two ears first meet, in the brainstem (Oster, 1973). The loops cross on the axis, where the pilot sits, and their two notes meet there, so the beat exists only in the pilot. That is the craft’s symbiosis, built into its mechanism: the craft plays two notes, and the tuning is complete only when the person inside joins them into one. The craft tunes its notes to the pilot’s DNA, so the beat forms cleanly in that person. The beat is the lock, not the clock: it joins pilot and craft before departure and confirms them at arrival, τ◇ = N◇ / ν◇ each time, and between the two the Resonance Cascade runs at the domains’ own Tempos. In it, Binary Pulse Theory meets itself in small: one pulse born between two states.
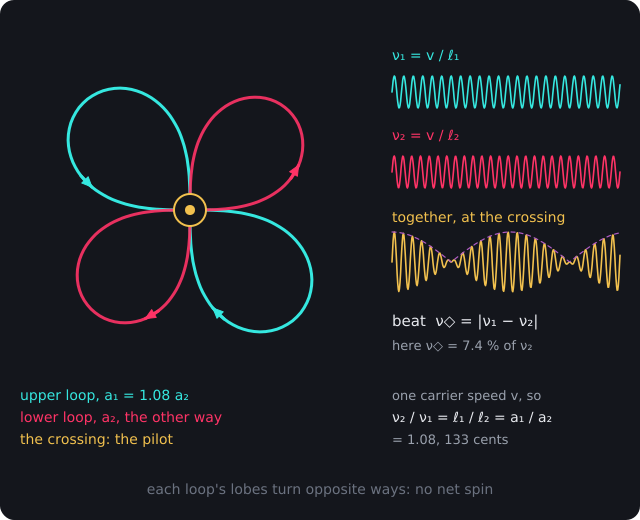
Binary Beat Loops. Two figure-8 loops, crossed at right angles and circulating in opposite senses, the upper 8 % larger. Each loop’s lobes turn opposite ways, so neither carries net spin. With one carrier speed the larger loop sounds the lower note, ν = v / ℓ, and the two notes beat at the crossing, ν◇ = |ν₁ − ν₂|, where the pilot sits.
The Still Centre
The pilot sits at the crossing, in a clear chamber inside a vacuum halo, where the two loops’ spin cancels: the order a Pulsecore keeps, a clear centre, its halo, and a toroidal rim around them. The craft is lens-shaped. Its rim is a torus. Its hull is the lattice in Zinf units, and a tuning band runs round the rim’s equator, stepping the lattice from one domain’s fundamental to the next by the Domain Interval.
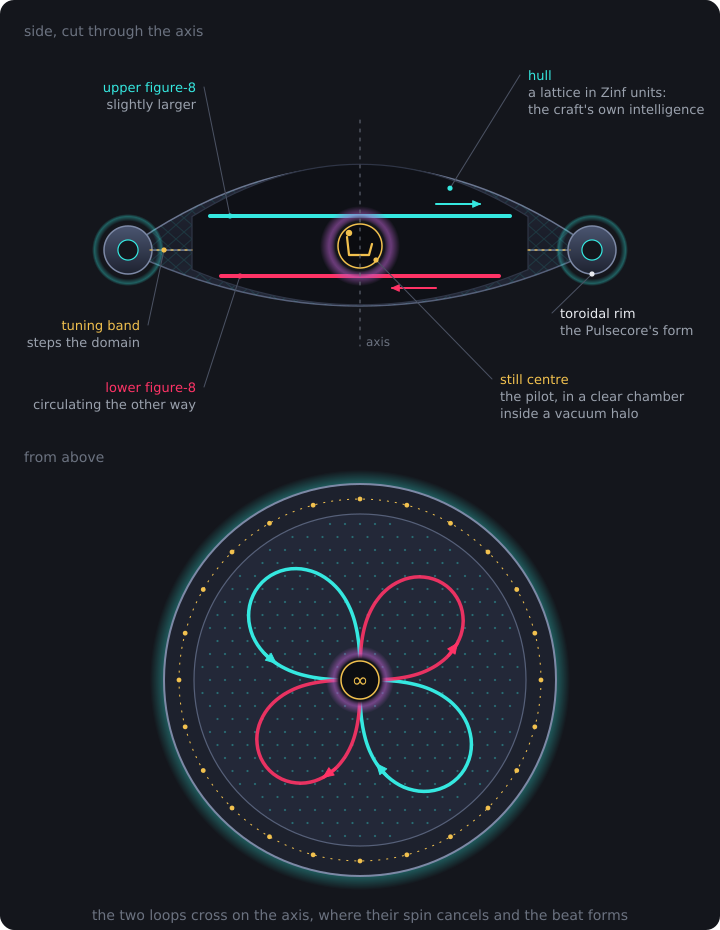
The Interdomain Craft. A design read from the theory, in a side cutaway and from above. The hull is a lattice built in Zinf units, which is also the craft’s intelligence; the rim is a torus with a tuning band at its equator; two counter-circulating figure-8 loops, the upper slightly larger, cross on the axis; and at their crossing, in a clear chamber inside a vacuum halo, sits the pilot, where the loops’ spin cancels and their beat forms.
The craft is a design read from the theory, not a result of it. The laws give the ladder of domains, the speed of their light, the time of a crossing and the notes of the loops; the craft is one way to use them, and how far a given craft can take a given body is set by the craft’s fidelity, F⇅, and the body’s tolerance, F_min, both to be measured. The Interdomain Calculator works every law of this Part from its inputs (/calculator/interdomain).
9.5 Testable Predictions
- Phase Synchronization Signatures: In separated atomic clock systems showing φ⛟(t) = φ▱(x,t) + Δφ⇄ correlations detectable with precision better than 10⁻¹⁸ s, observable through cross-correlation analysis of globally distributed precision timing networks.
- Quantum Entanglement Phase Timing: Exhibiting |ψ⌭⟩ = Σ_n α_n × exp(i φ_n) × |n⟩ state evolution patterns in quantum communication experiments, measurable via quantum state tomography revealing controlled phase evolution dynamics.
- Gravitational Wave Phase Modulation: Detectable in interferometer data following ∇²φ = (1/𝒞→²) × (∂²φ/∂t²) + ρ⥂ × (4πG/𝒞→²) field equations with sensitivity of 10⁻²¹, identifiable through advanced data analysis techniques isolating substrate-induced phase variations.
- Superconducting Circuit Phase-Locking: Demonstrating controlled navigation through substrate phase manipulation in laboratory conditions, achievable via cryogenic circuit implementations maintaining coherent phase control over extended periods.
- Navigation Efficiency Scaling: With I⟢ = log₂(N↑ × N↓ × N∠ × N⇉) information capacity per Pulse, quantifiable through navigation performance metrics demonstrating exponential efficiency improvements.
- Phase Attractor Convergence: Following lim_{n→∞} |φ▷(t + nτ) - φ⨷| = 0 in long-term trajectory evolution, verifiable through extended trajectory tracking demonstrating asymptotic Phase Stability.
These predictions could establish a framework for advanced navigation through computational substrate manipulation, opening possibilities for propulsion systems based on phase dynamics rather than conventional acceleration, while maintaining strict relativistic compliance.